
AI Robotics · Enabling research
Surgical Intelligence and Medical Computer Vision
Computer vision and medical AI that connect anatomical information with surgical planning and robotic control.
ENGINEERING IN MOTION
Look closer.
Precision is in the details.
Three perspectives on surgical robotics.
Explore the Precision Arm, ROSA, and da Vinci.
Explore the ROSA arm, wrist, and stereotactic instrument guide.
Interactive 3D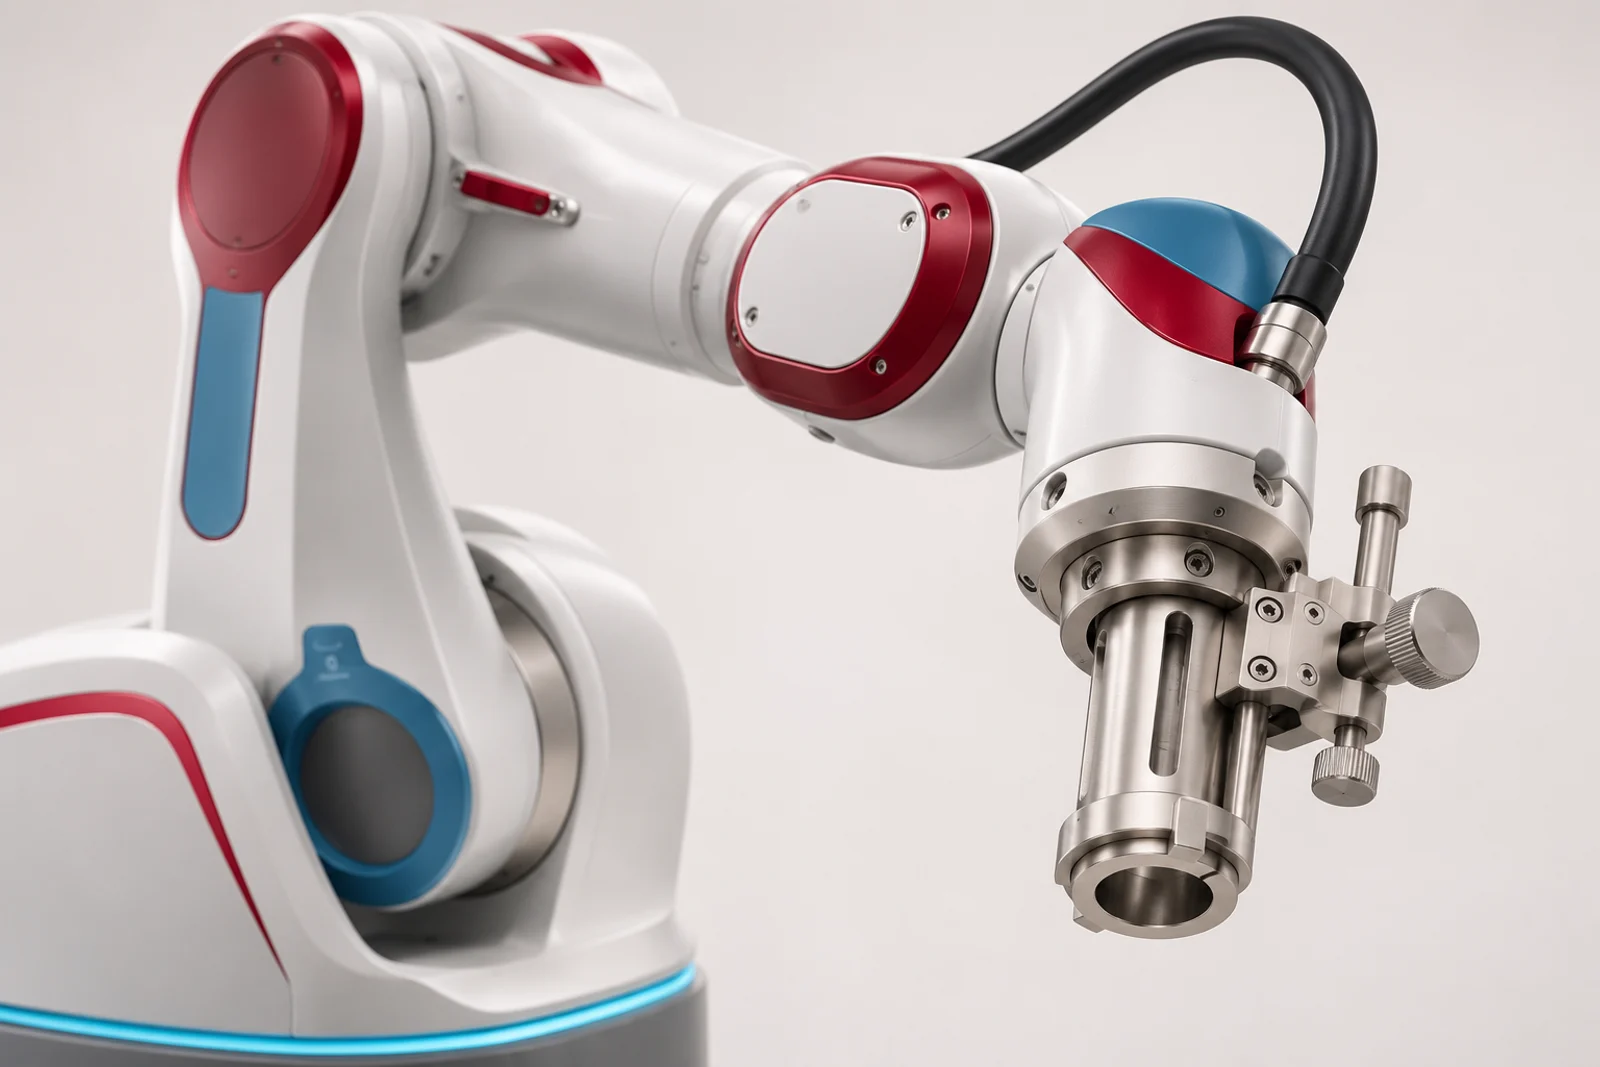
3D visualization
A platform for precise neurosurgical access.
Explore the distinctive compact arm and articulated joints. Our work on new ROSA instrumentation connects this mechanical foundation with AI perception, planning, and control.
ROSA is a Zimmer Biomet platform. Platform details ↗
Understanding medical images
Our medical computer vision work examines anatomy, image features, and spatial relationships. The aim is to make complex imaging information useful within a defined surgical workflow.
Connecting information
Images, instrument position, and sensor observations provide different views of the same environment. We investigate how these inputs can be aligned and interpreted together.
From interpretation to planning
Anatomical information supports decisions about access, trajectories, boundaries, and instrument movement. Our work connects these planning questions with the requirements of robotic control.
Sensing and feedback
The surgical environment can change during a procedure. Feedback, localization, and continuous checks help connect the plan with what instruments and sensors observe.
Collaborate with us
We welcome imaging specialists, computer vision researchers, clinicians, and robotics engineers working on related questions. Contact our team to discuss data, methods, and technical scope.